Felix Dülmer
Ph.D. Candidate
I am a Ph.D. candidate in computer science at the Technical University of Munich, supervised by Prof. Nassir Navab at the Chair for Computer Aided Medical Procedures and affiliated with the Institute of Biological and Medical Imaging. My research combines learning-based scene representations with physical models of ultrasound image formation, with a focus on differentiable rendering, novel view synthesis and robot-assisted acquisition.
In 2026, I was a visiting researcher in Prof. Jeremy Dahl's lab at Stanford University, working on differentiable speed-of-sound estimation.
- CV: Download (PDF)
- Location: Munich, Germany
- Email: felix-duelmer@online.de
News
Publications
Selected works are highlighted.
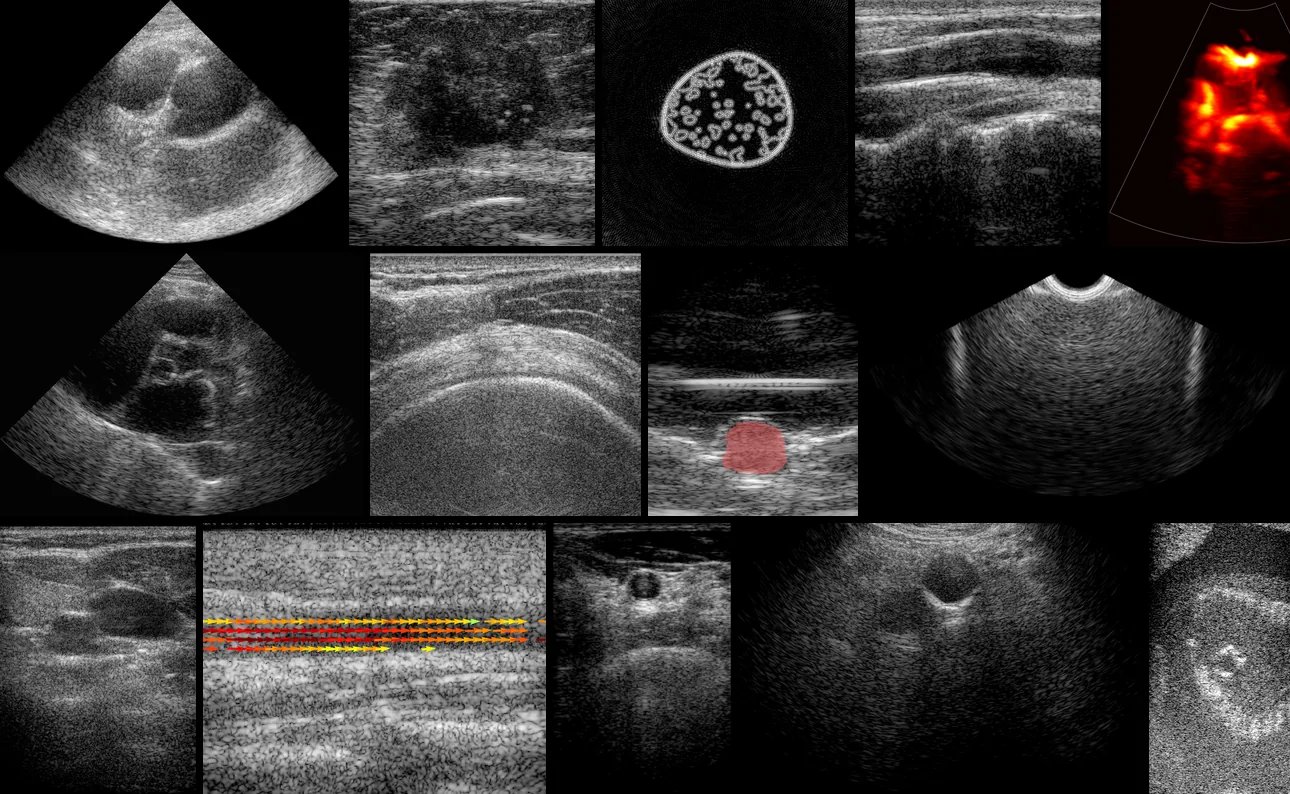
OpenH-RF: Open Ultrasound Channel Data
Open data initiative led by Stanford, TU/e & NVIDIA · 38 institutions · arXiv:2610.13616
The largest openly licensed dataset of pre-beamformed medical ultrasound measurements: 19,336 real and synthetic channel captures for training raw-to-insight foundation models (CC BY 4.0).
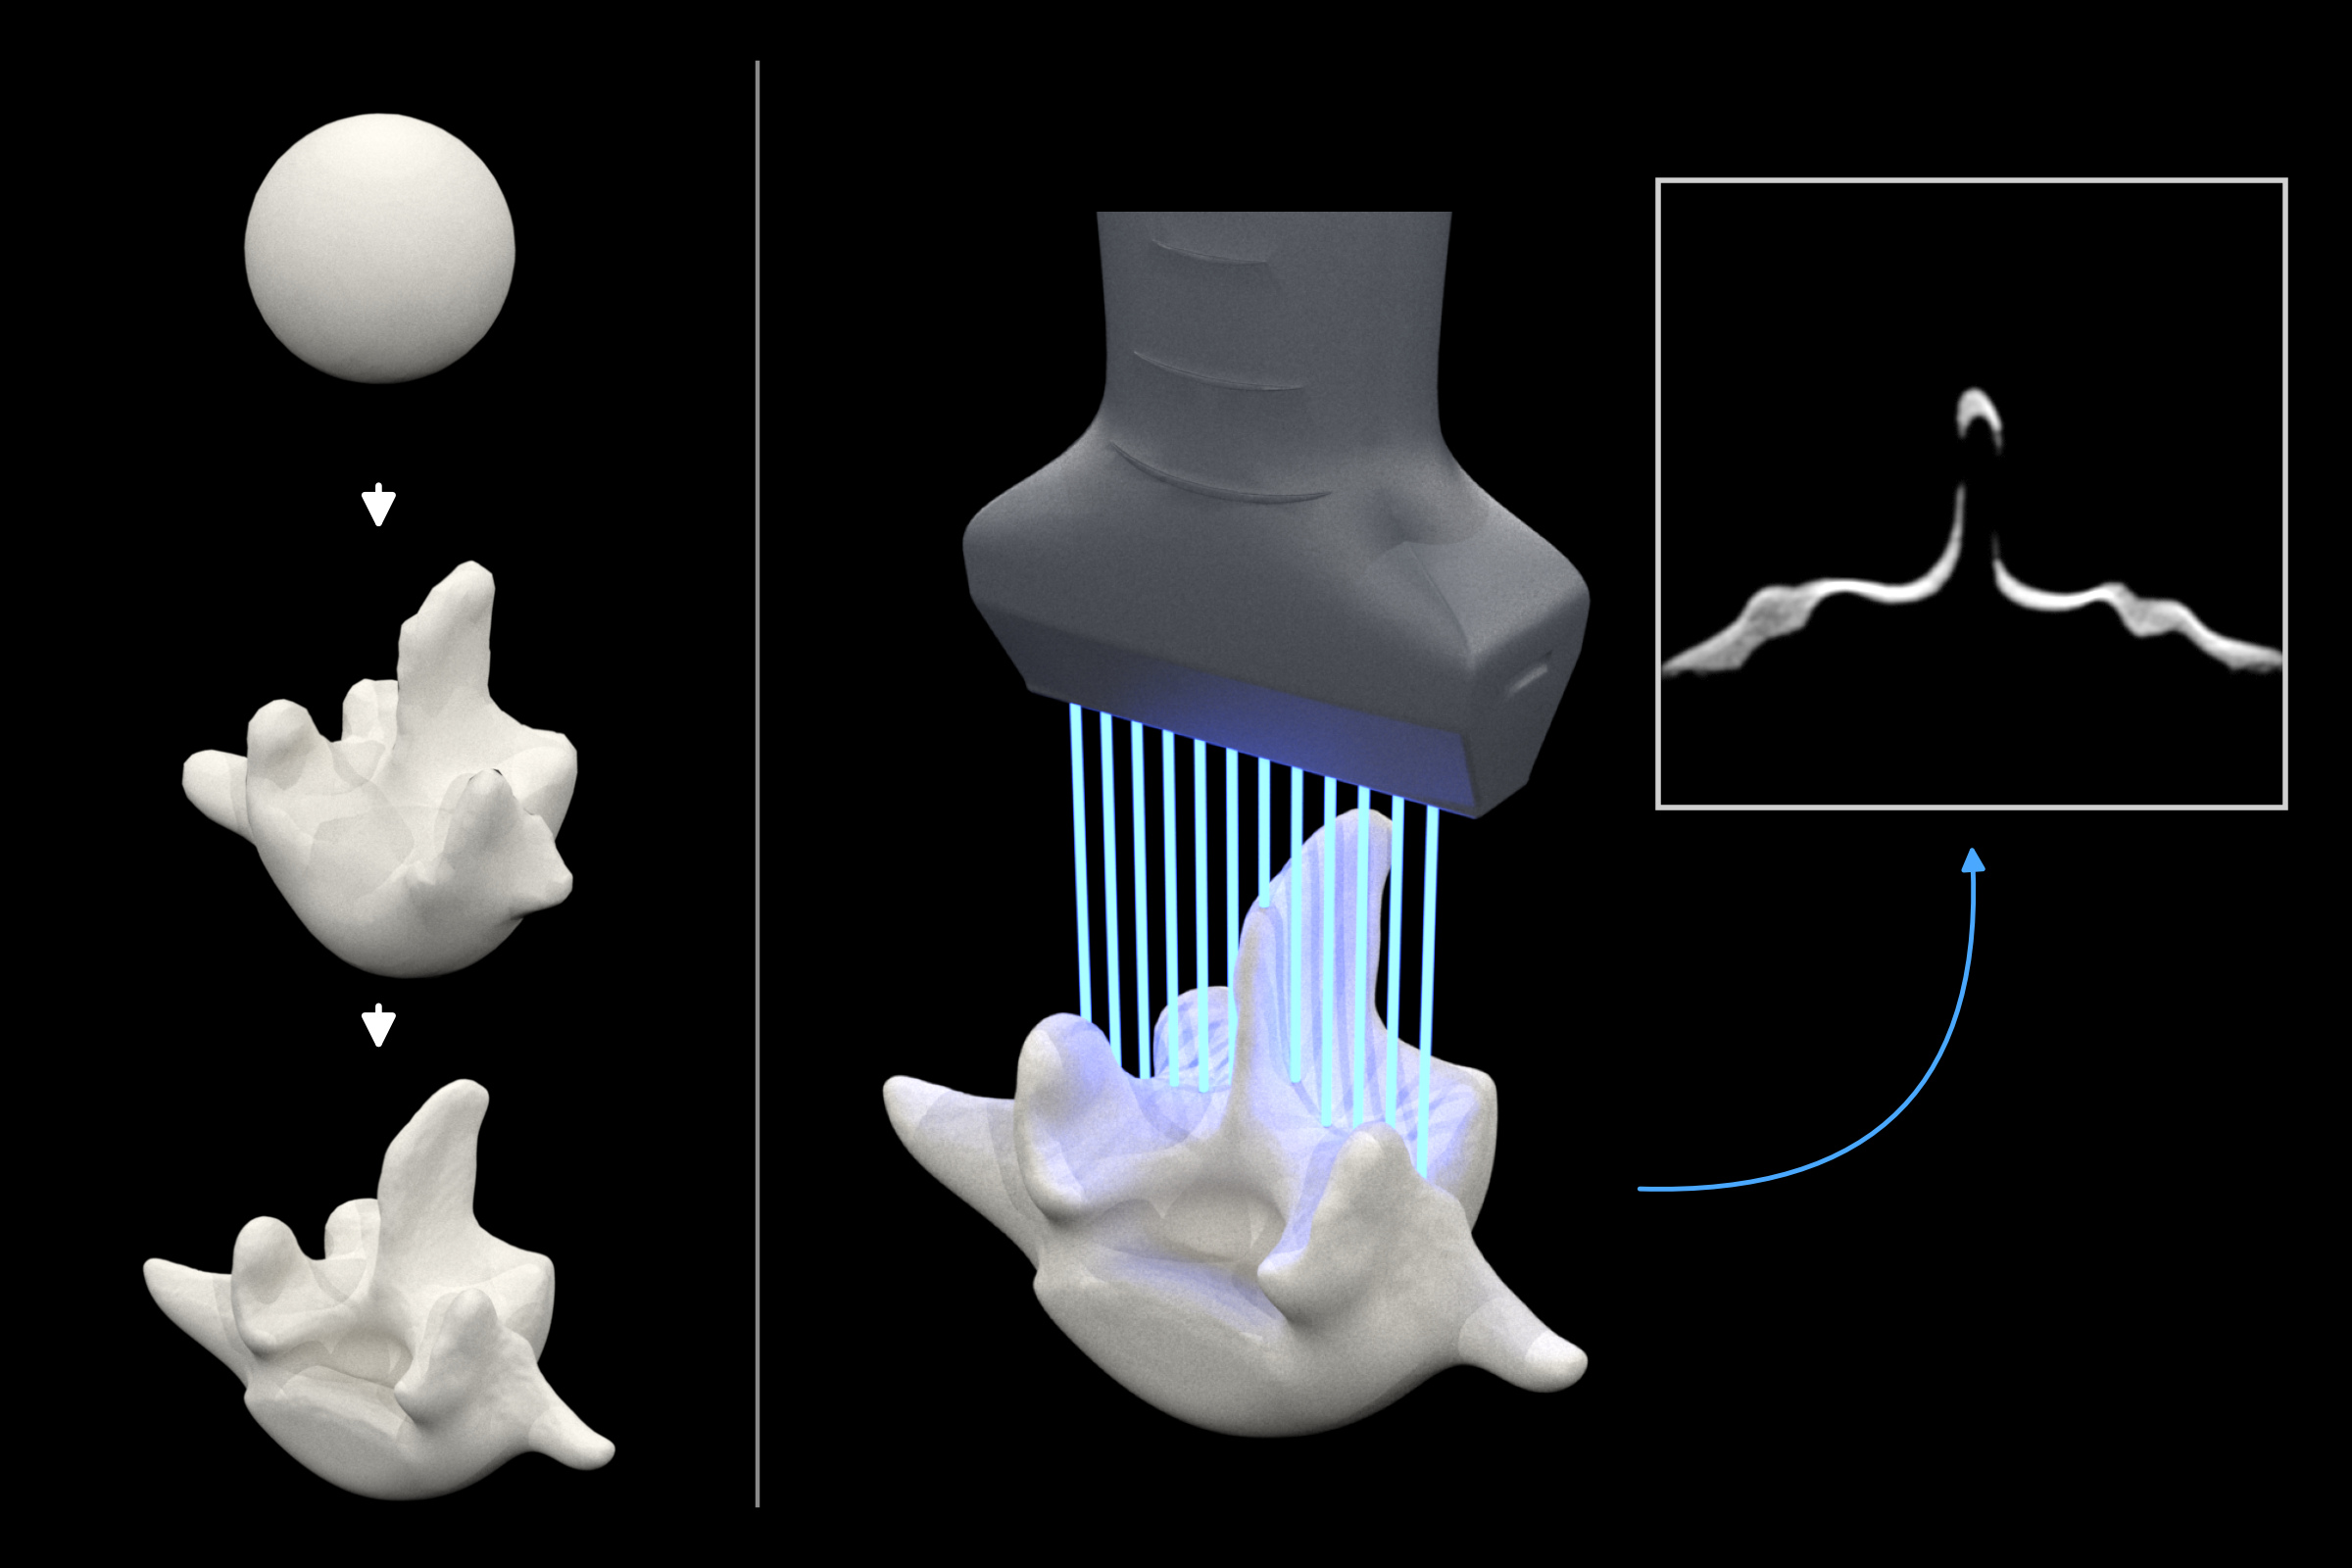
UltraDiff: Differentiable Ray Tracing in Ultrasound for Shape Optimization
SIGGRAPH Asia 2026 Technical Communications (Kuala Lumpur, Malaysia) · arXiv:2610.07941
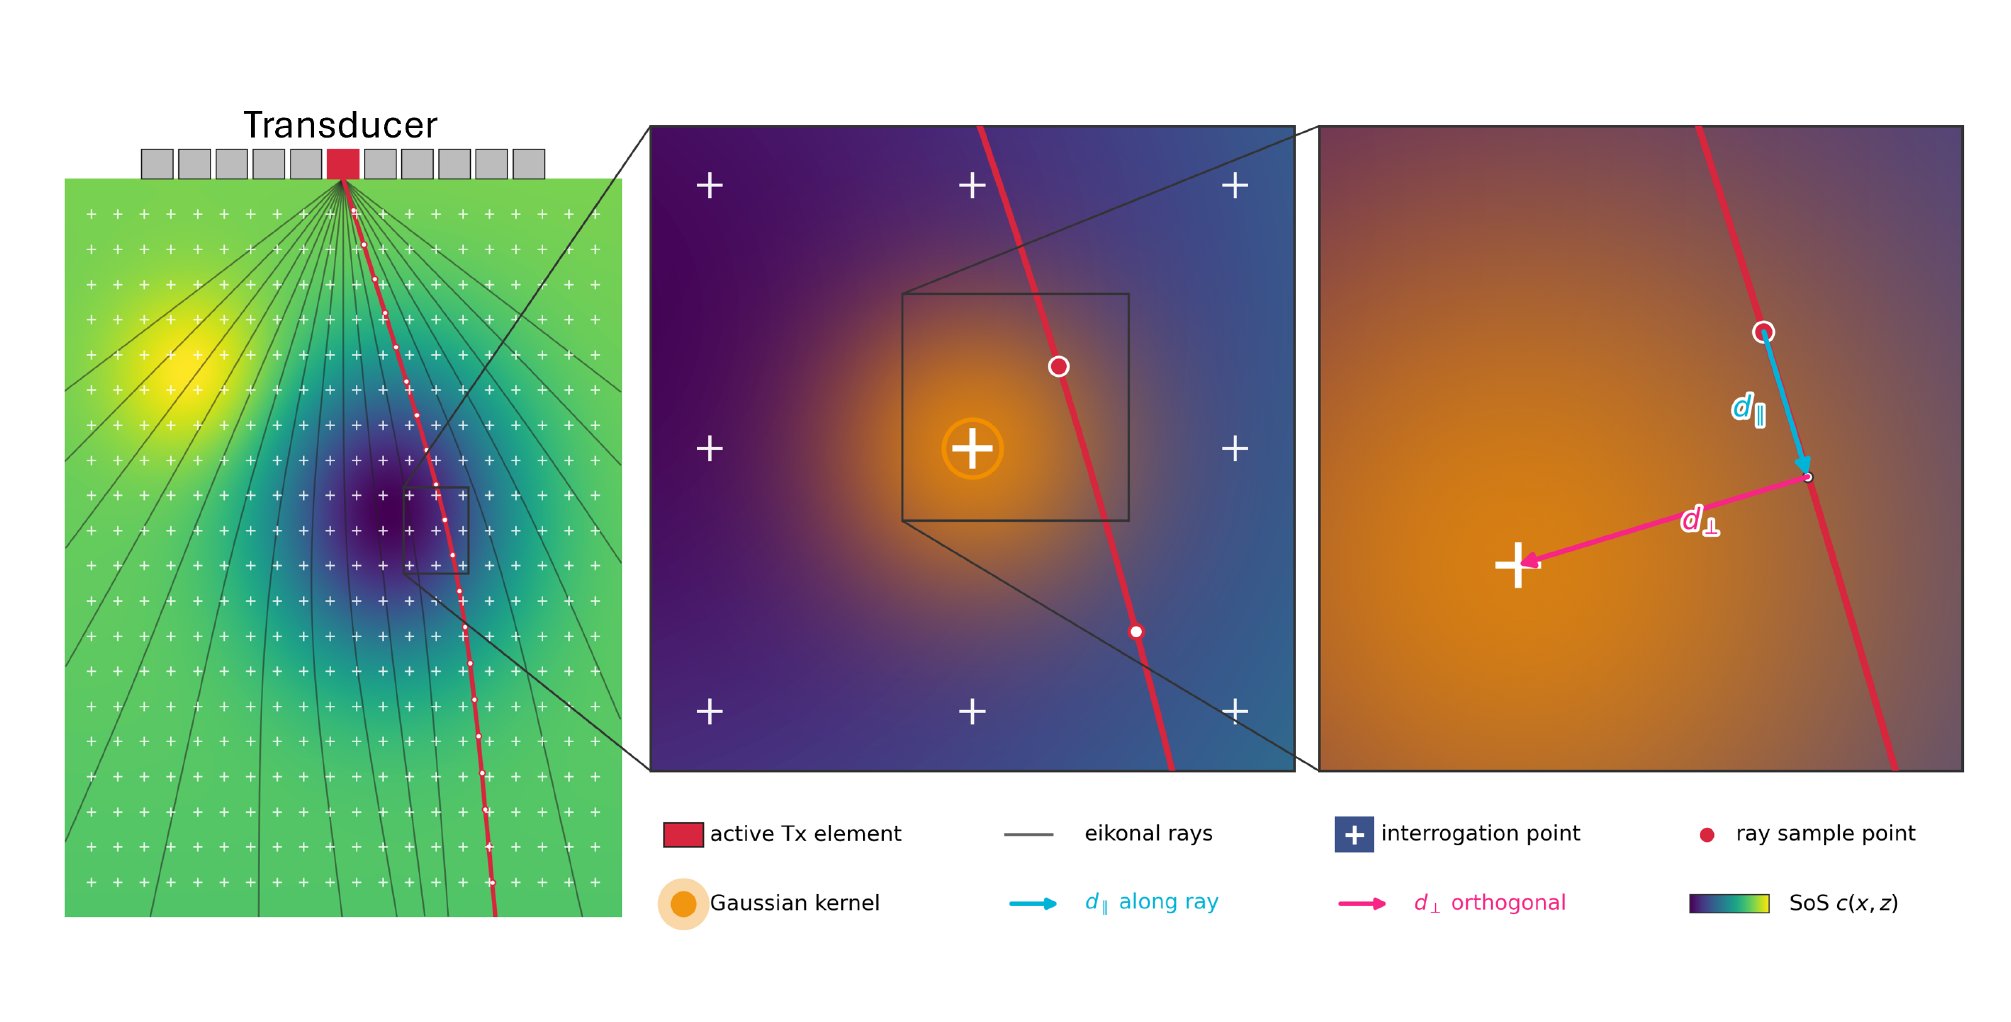
UltraBend: Refraction-Aware Propagation Modeling for Speed of Sound Imaging in Ultrasound
ASMUS 2026 (MICCAI Workshop)
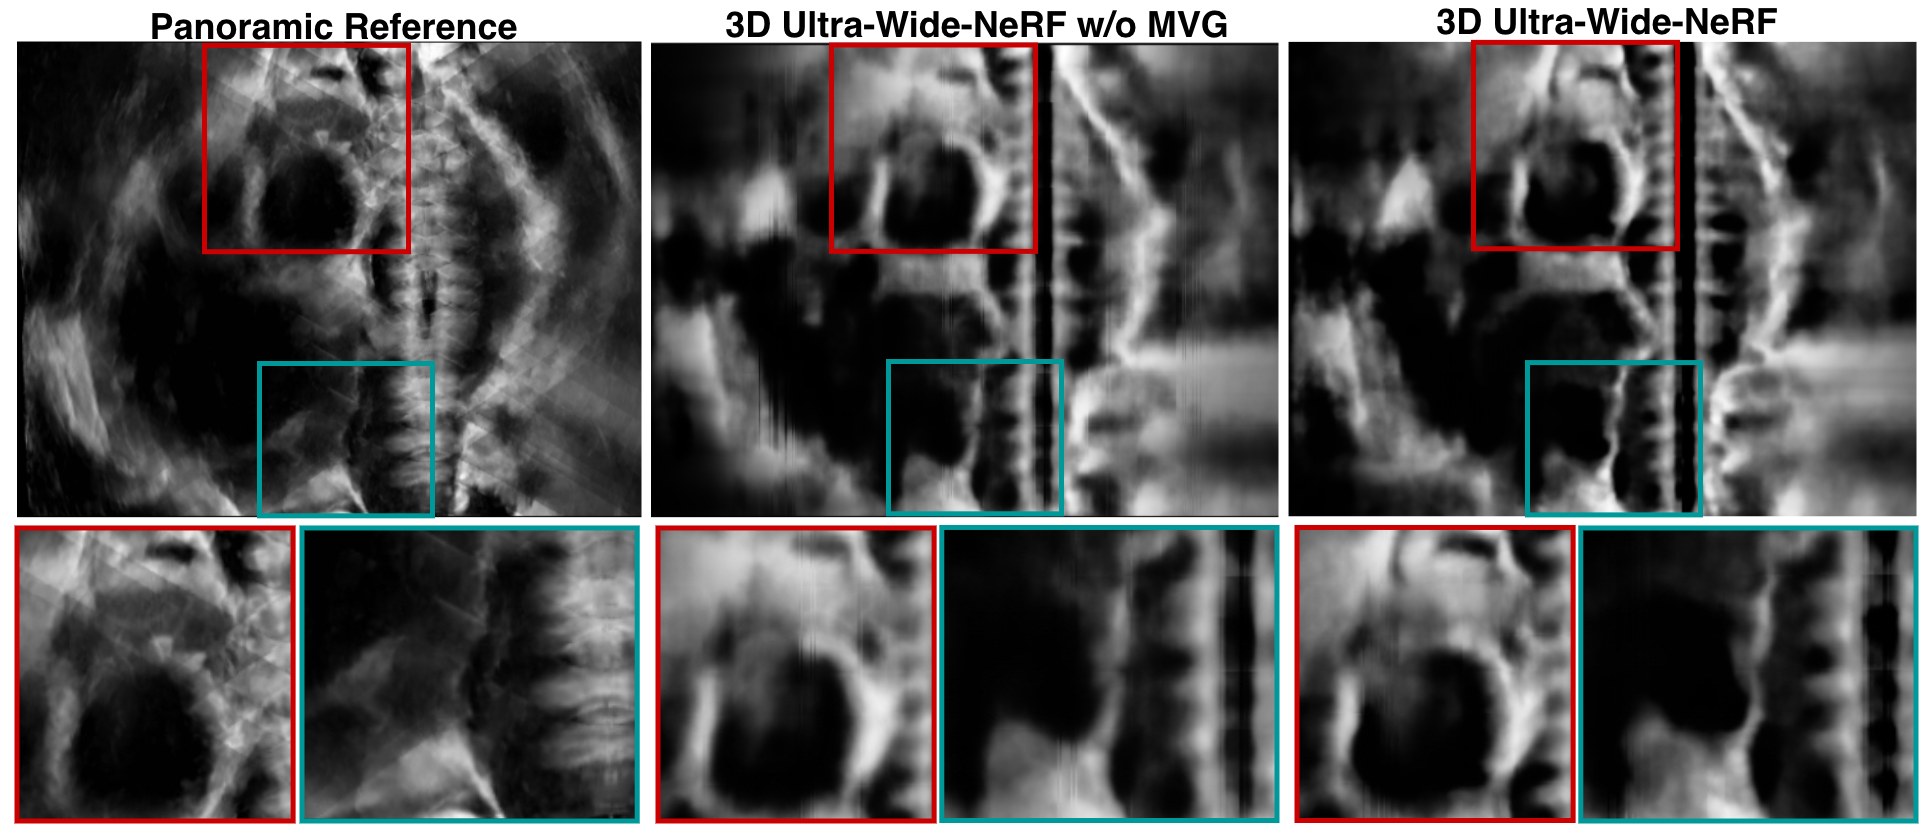
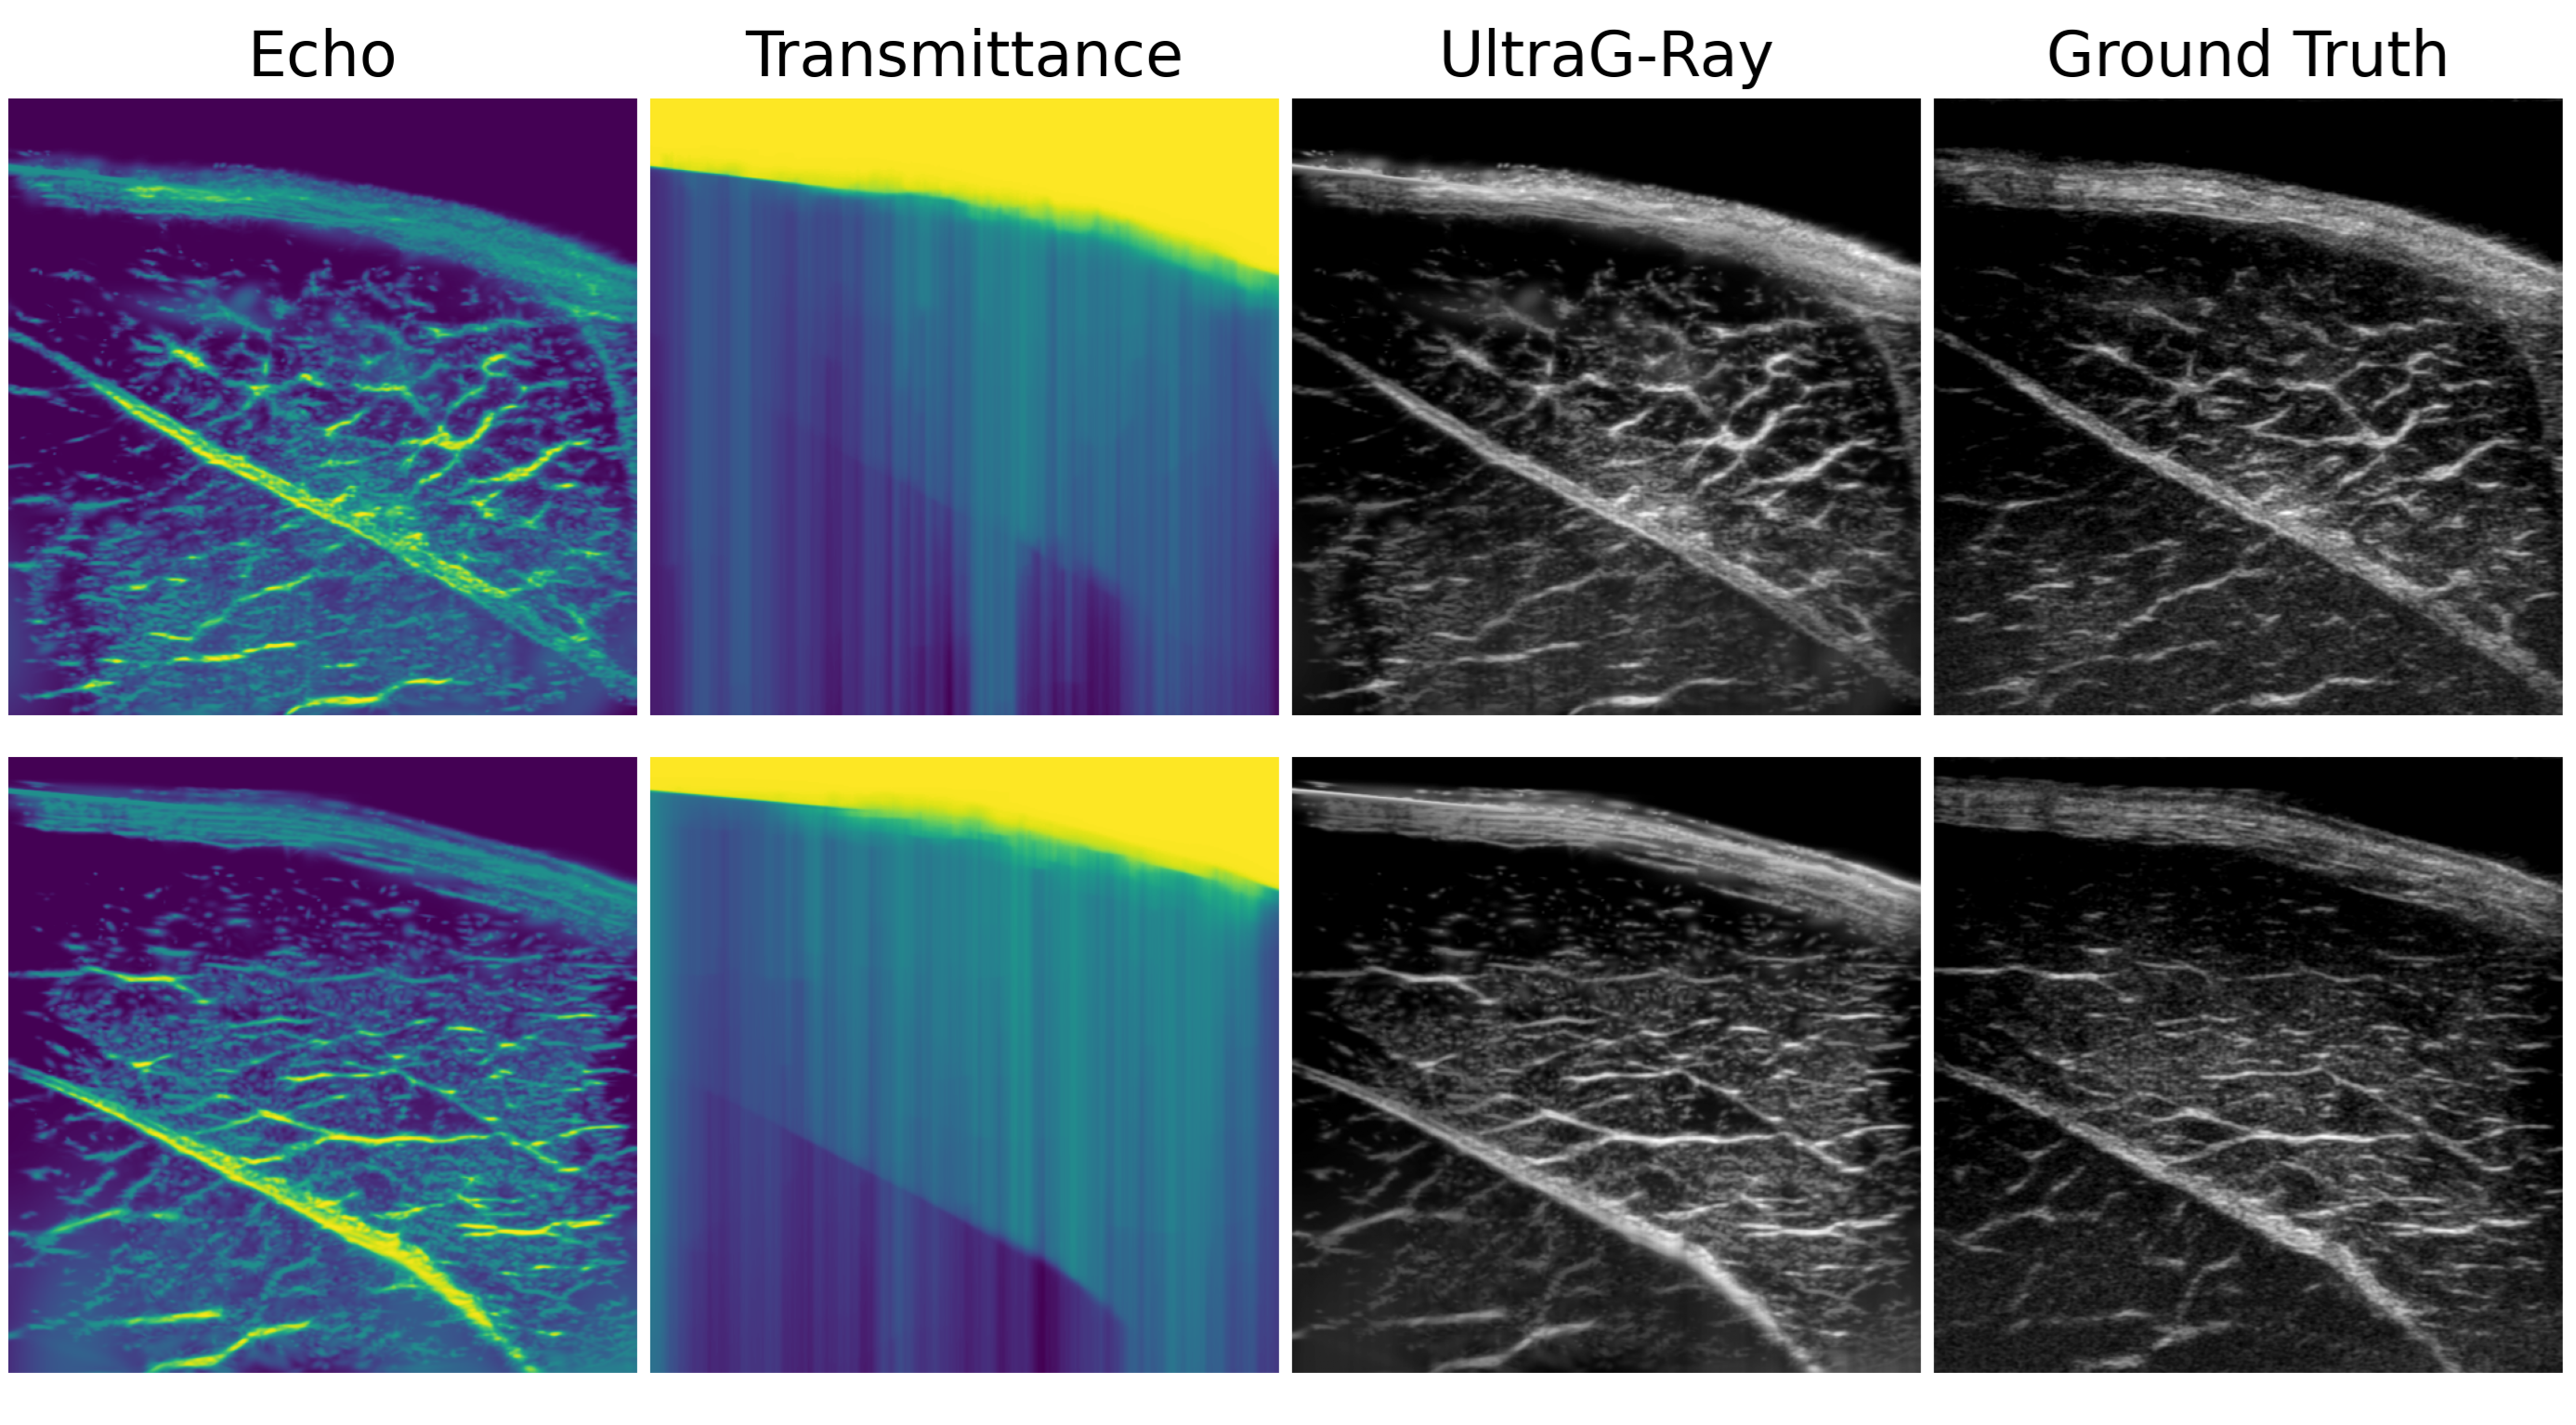
UltraG-Ray: Physics-Based Gaussian Ray Casting for Novel Ultrasound View Synthesis
MIDL 2026 · arXiv:2603.29022
Translational Research and Clinical Trends in Robot-Assisted Vascular Surgery: A Narrative Overview
Book chapter · Handbook of Robotic and Image-Guided Surgery, 2nd ed. (Elsevier, 2026)
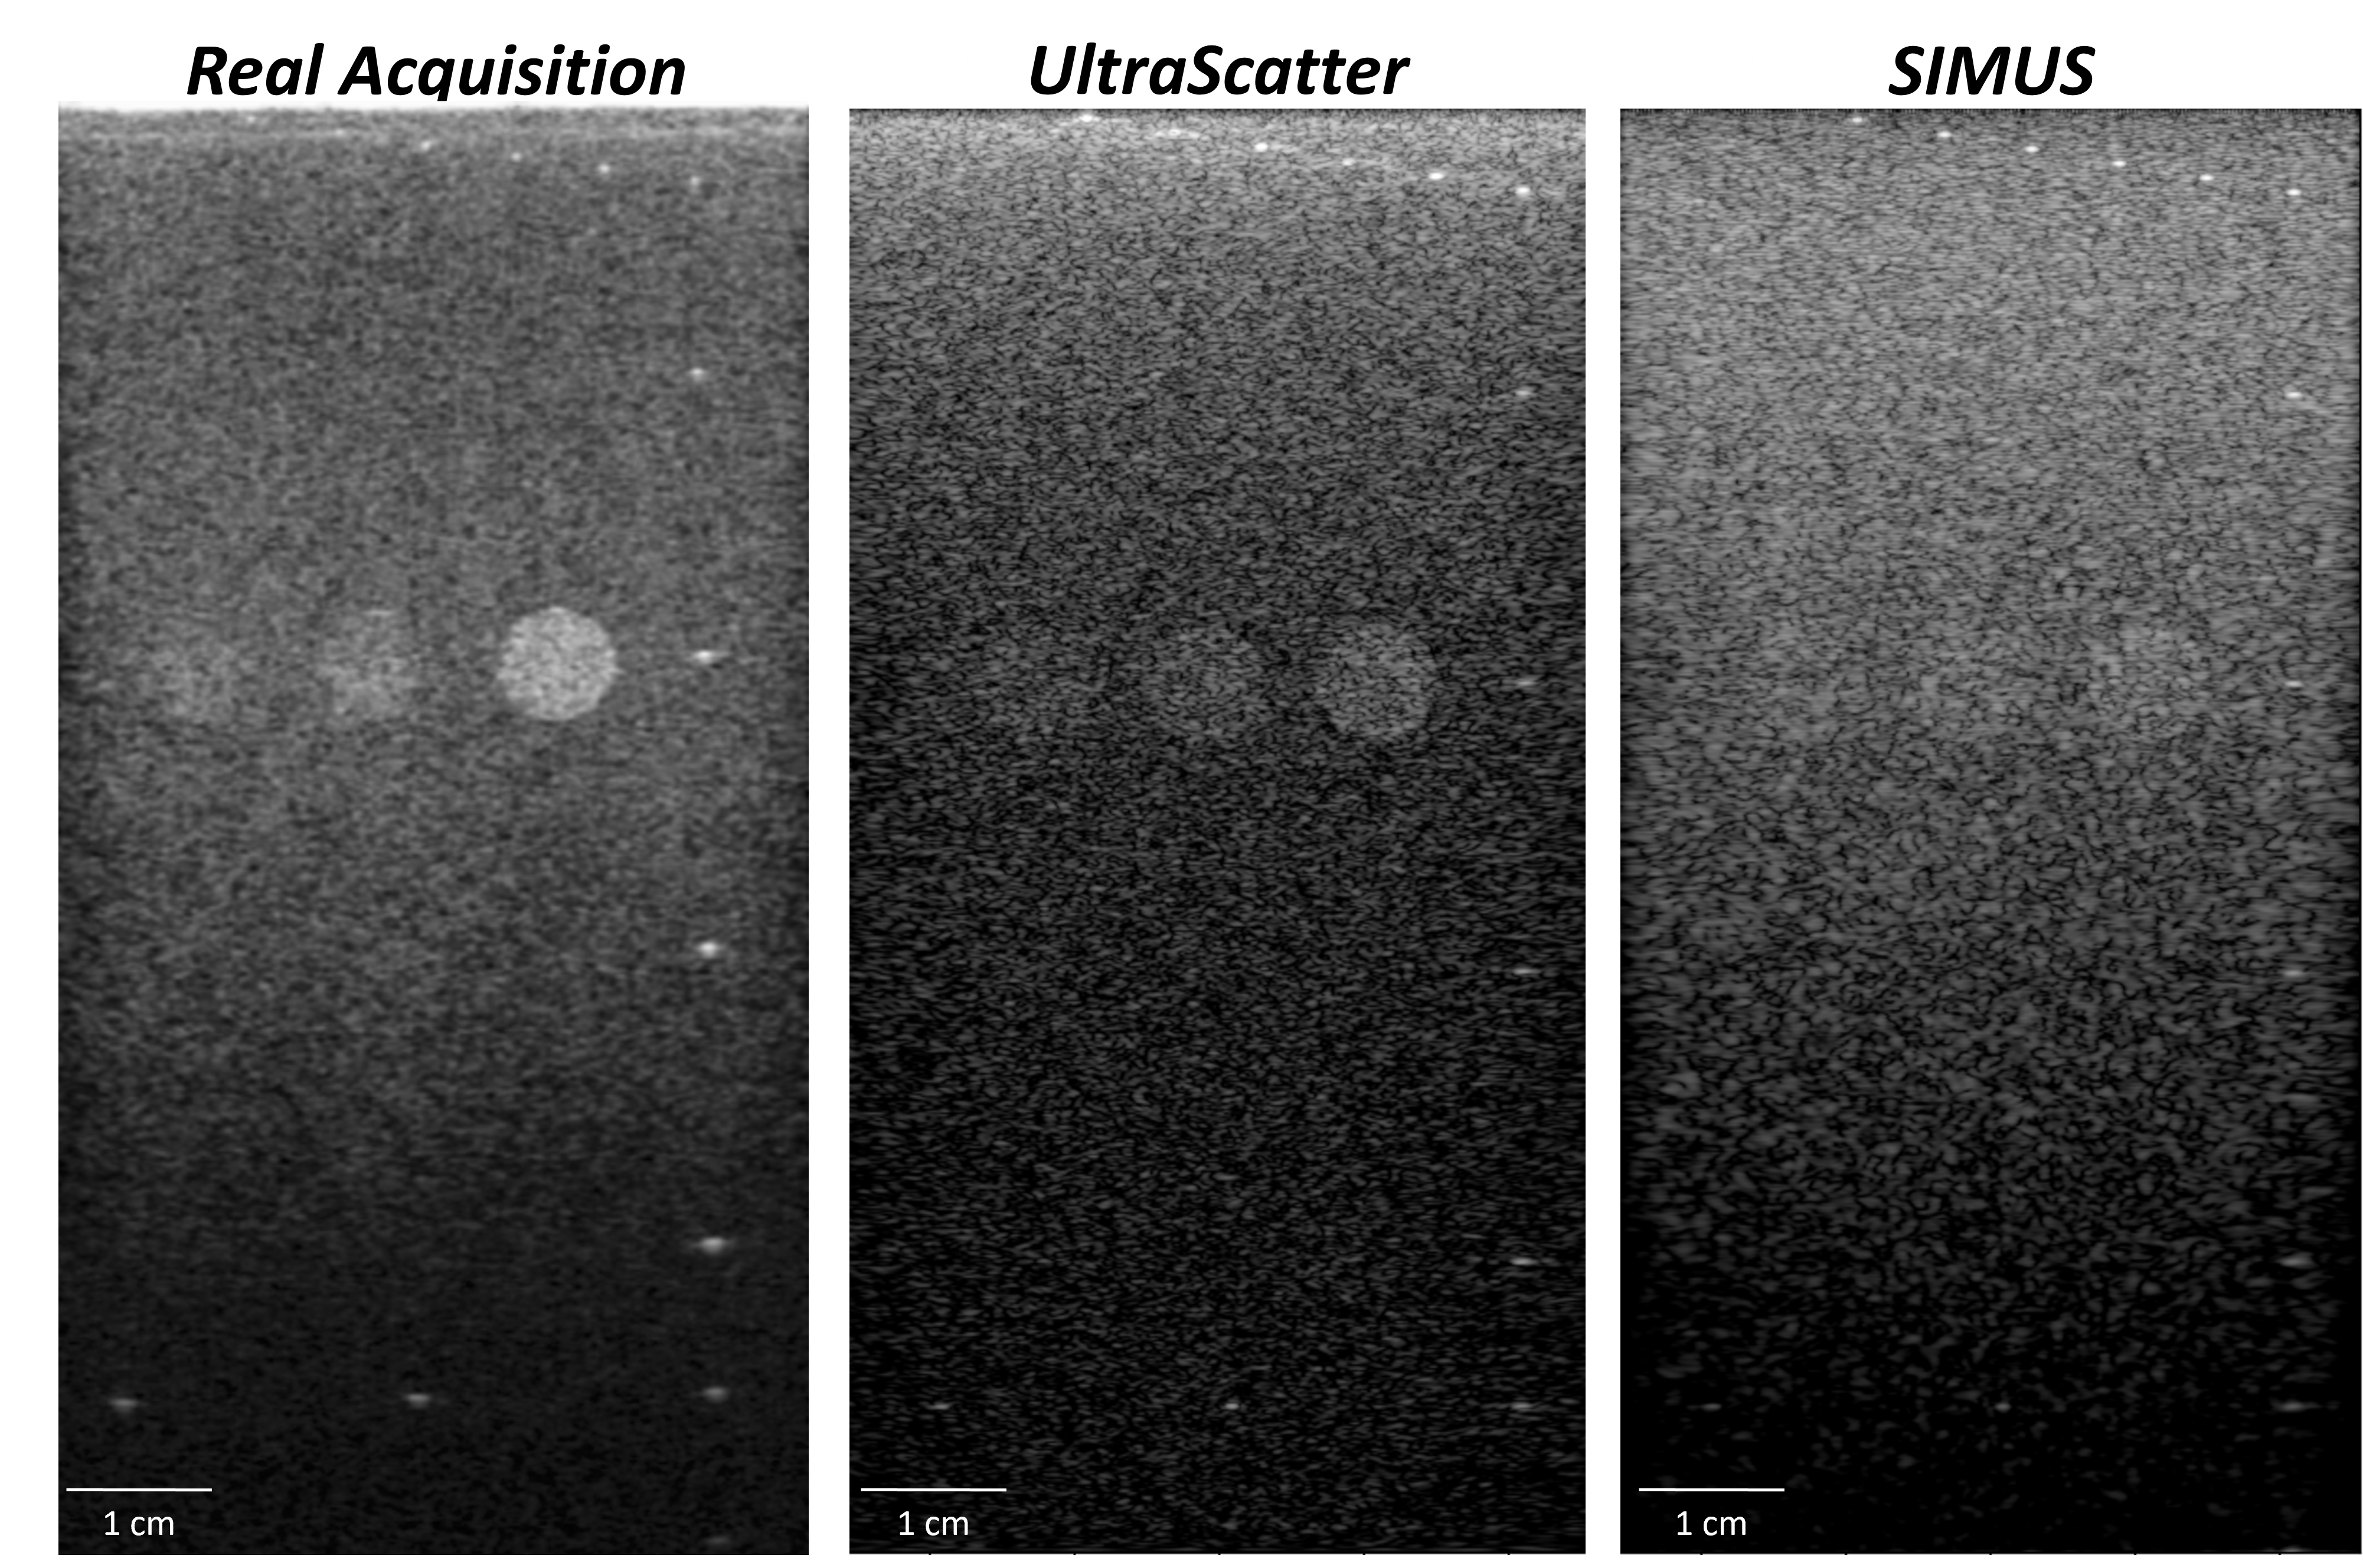
UltraScatter: Ray-Based Simulation of Ultrasound Scattering
IEEE IUS 2025 (Utrecht, Netherlands) · arXiv:2510.10612
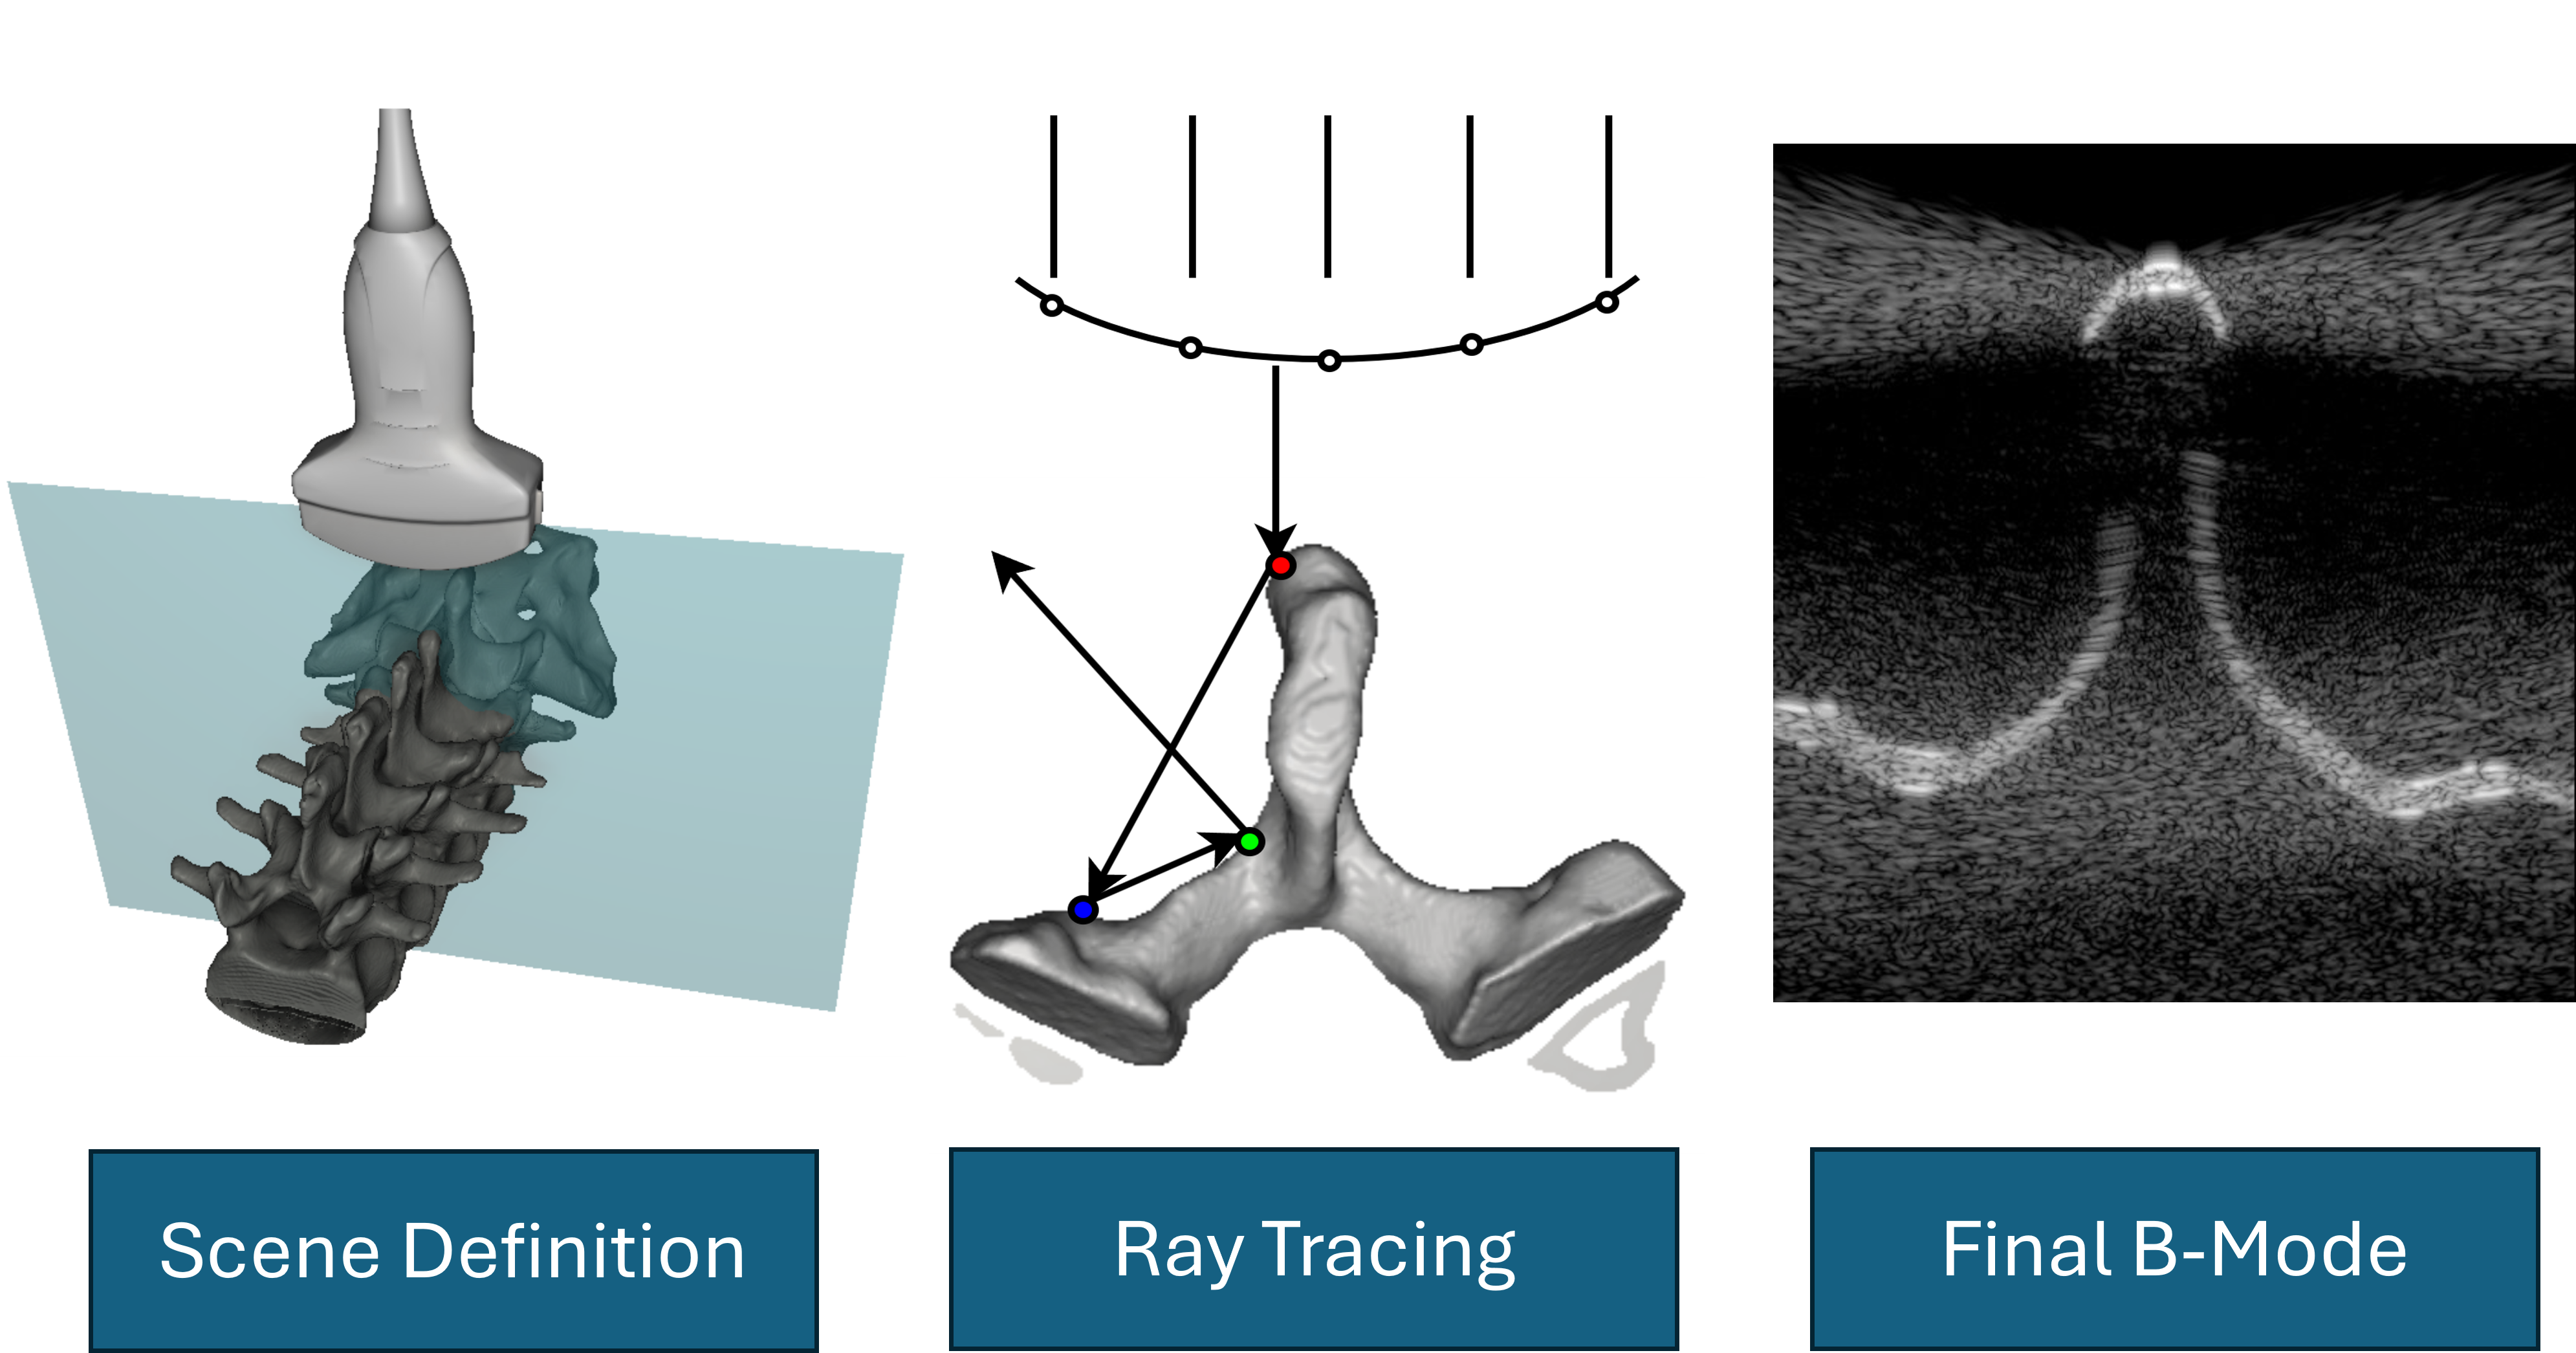
UltraRay: Introducing Full-Path Ray Tracing in Physics-Based Ultrasound Simulation
MICCAI 2025 · arXiv:2501.05828
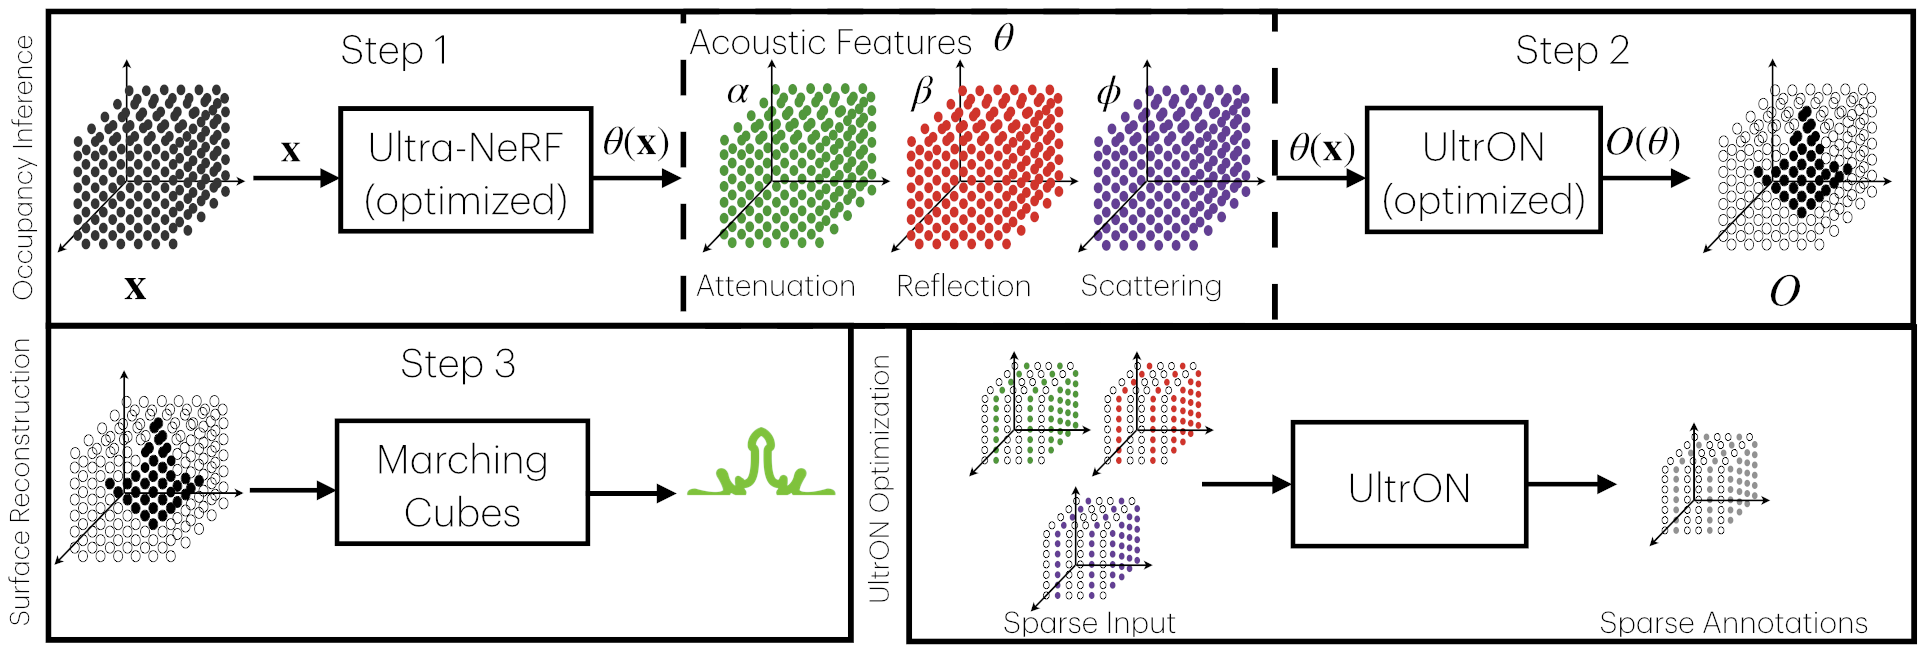
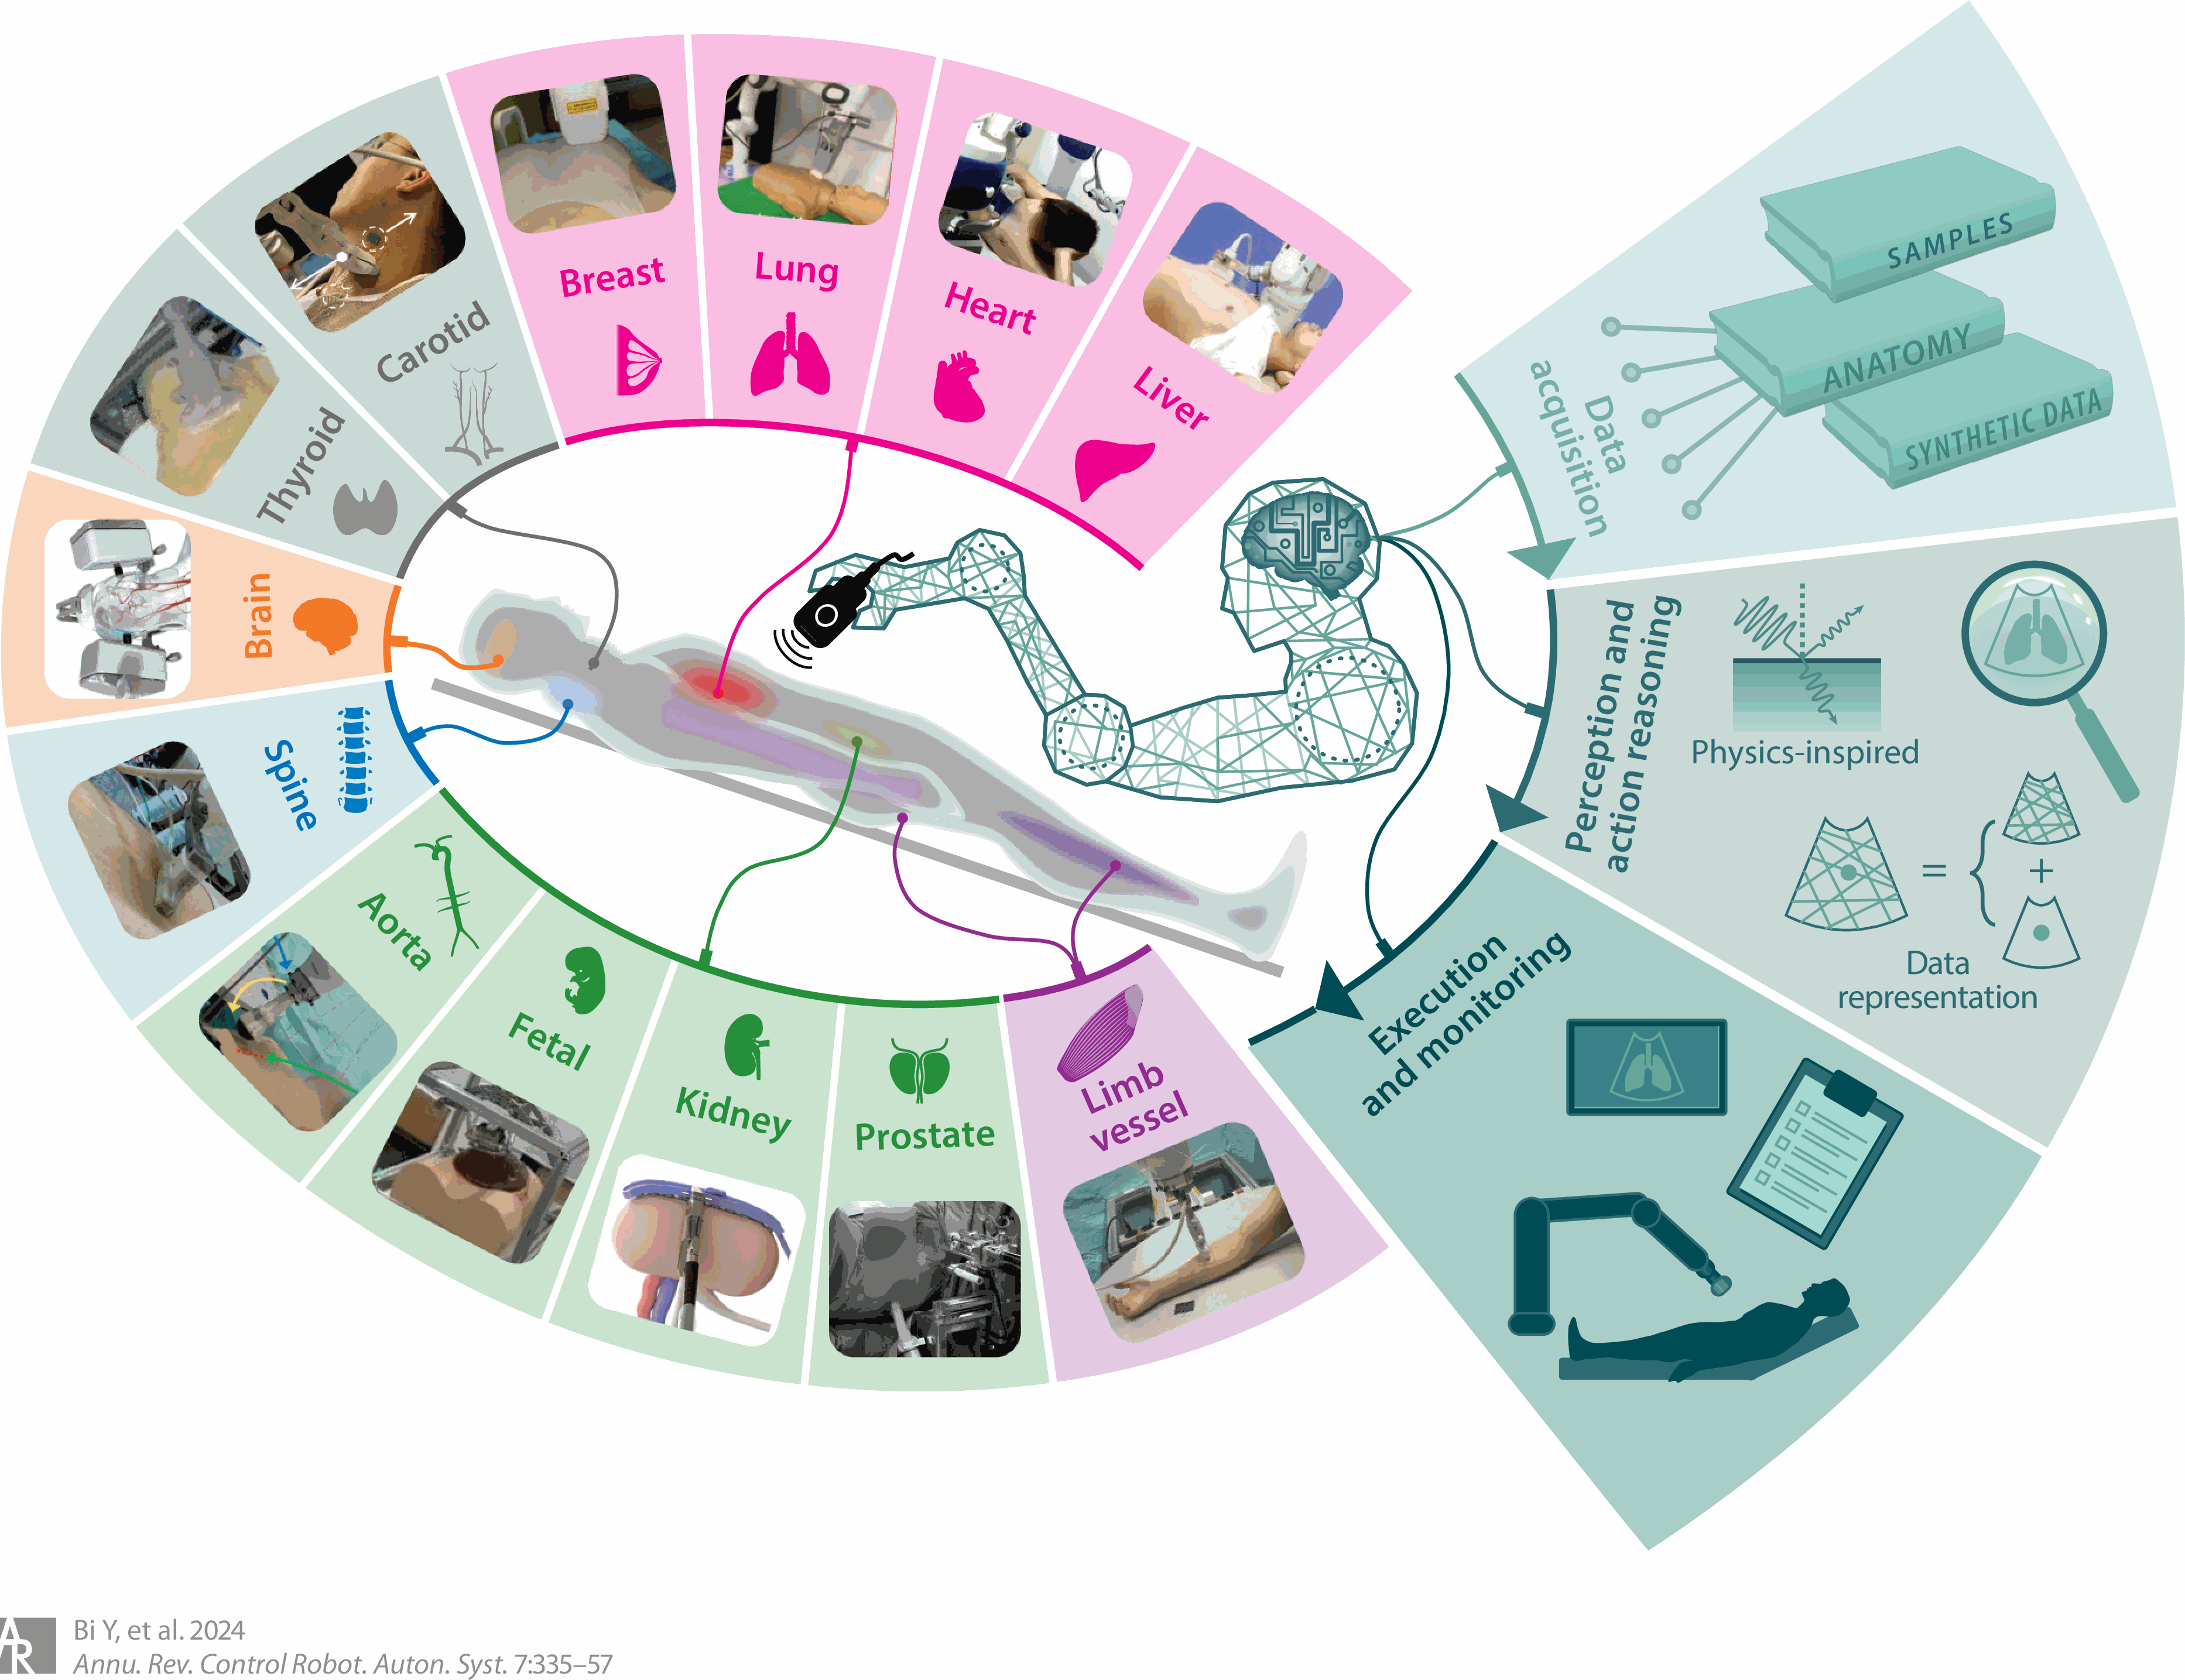
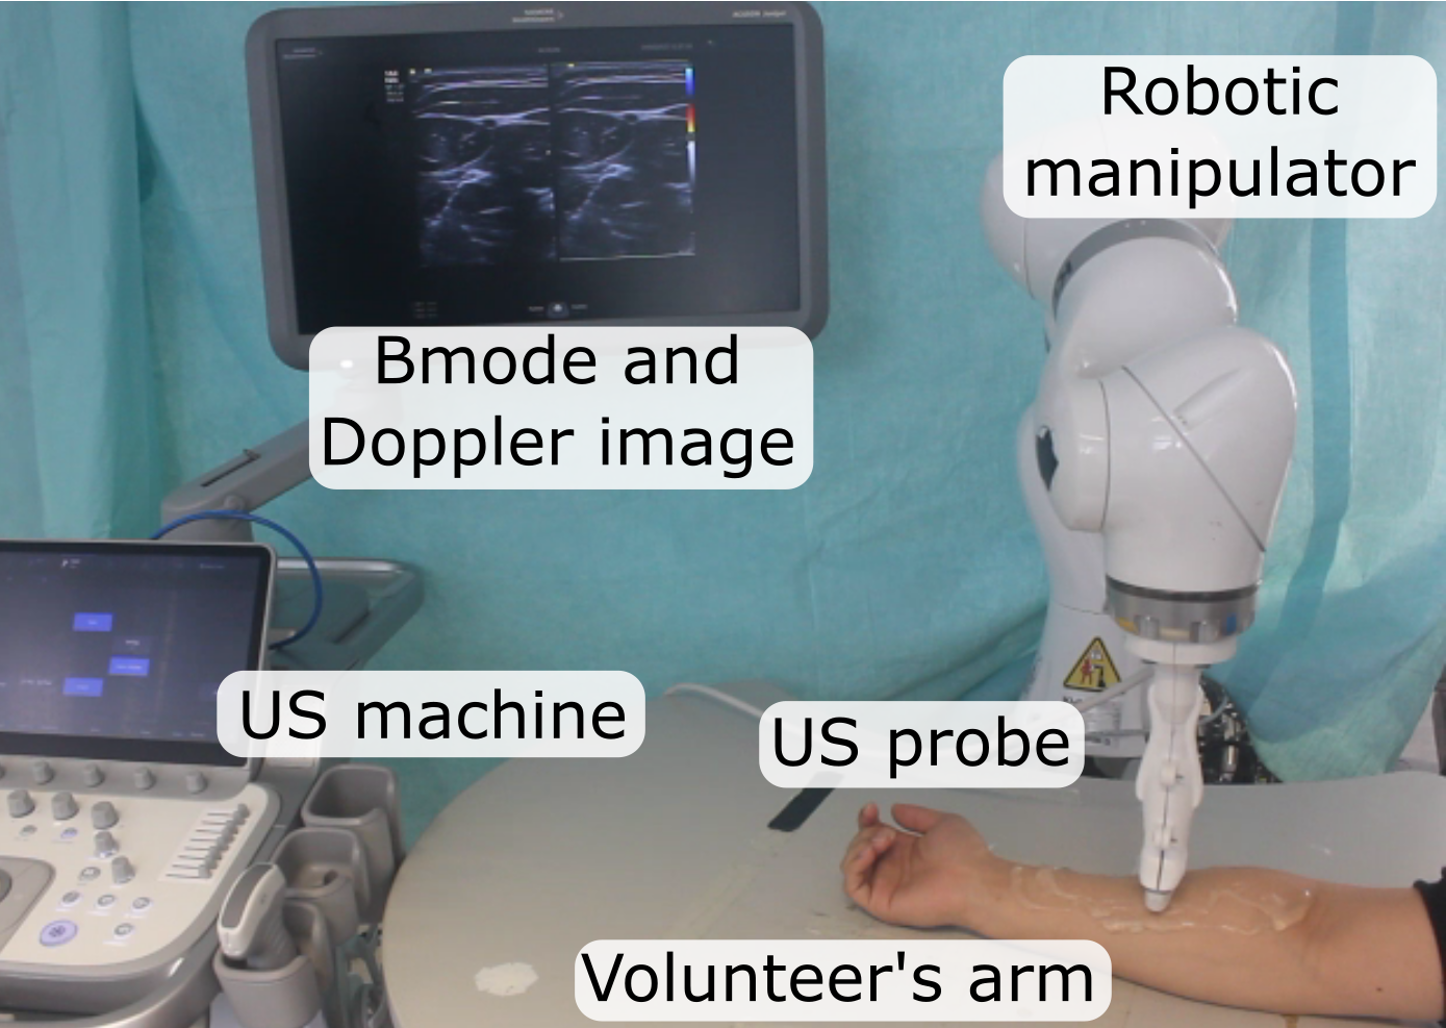
Machine Learning in Robotic Ultrasound Imaging: Challenges and Perspectives
Annual Review of Control, Robotics, and Autonomous Systems (2024)
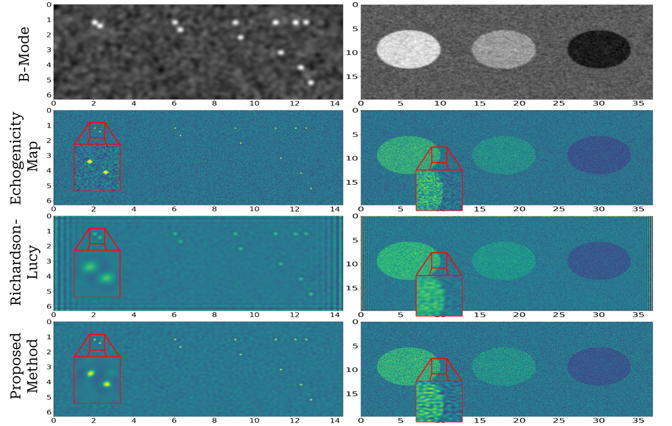
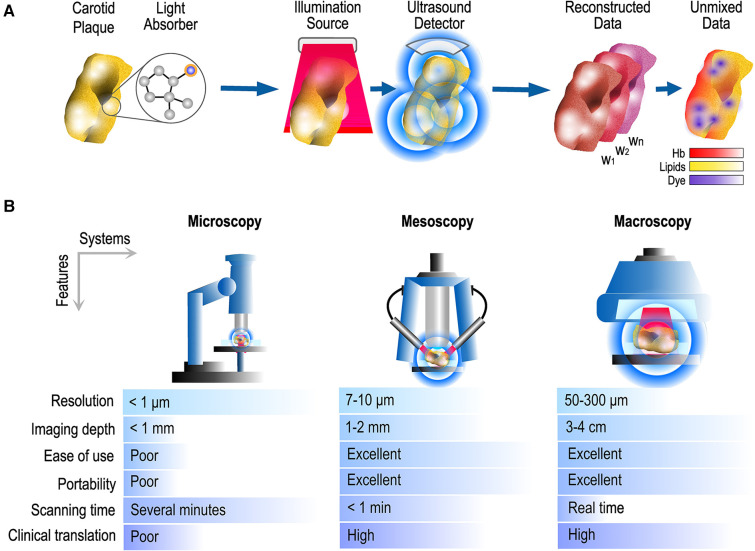
Optoacoustic biomarkers of lipids, hemorrhage and inflammation in carotid atherosclerosis
Frontiers in Cardiovascular Medicine (2023)
Experience
Visiting Researcher
03/2026 – 05/2026
 Stanford University, Ultrasound Imaging and Instrumentation Lab (Prof. Jeremy Dahl), Stanford, CA, USA
- Developed differentiable ultrasound image-formation models grounded in acoustic propagation physics.
- Worked on continuous speed-of-sound representations using bent-ray tracing, differentiable ray-time modeling, and physics-based optimization.
Working Student — Mobile Software Developer
04/2021 – 12/2022
 Workerbase GmbH, Munich, Germany
- Developed and maintained two cross-platform industrial mobile applications deployed to several thousand factory workers
- Worked with Android (Kotlin, Java), iOS (Swift), and Flutter (Dart) for scalable cross-platform development
- Applied clean architecture, design patterns, and test-driven development
Research Assistant
09/2017 – 08/2020
 Technical University of Munich, Germany
- Maintained and extended a driving simulator for automated driving research
- Onboarded and trained students on simulator usage and associated software platforms
- Contributed to prototype development for higher levels of vehicle autonomy
Education
Ph.D. in Computer Science
01/2023 – Present
Technical University of Munich, Germany
- Ph.D. research in medical imaging, robotics, and physics-based simulation
- Focus on ultrasound imaging, novel view synthesis, and differentiable rendering
- Development of learning-based scene representations with physical image formation models
- Robot-assisted ultrasound acquisition and analysis
M.Sc. Mechatronics and Robotics
10/2018 – 09/2022
Technical University of Munich, Germany
- Specialization in robot-assisted medical systems and image-guided interventions
- Development of robotic and software prototypes for medical applications
Exchange Semester (M.Sc.)
07/2019 – 12/2019
 Universidad de los Andes, Colombia
- Coursework in big data analytics, deep learning, and numerical optimization
- Applied data-driven methods to large-scale and high-dimensional datasets
Term Paper — Cognitive Systems Lab
04/2019 – 06/2019
 University of Tsukuba, Japan
- Designed and evaluated a tactile steering wheel for autonomous driving
- Conducted a controlled user study on a Japanese cohort with synchronized EEG recordings
B.Sc. Mechanical Engineering
10/2014 – 10/2018
Technical University of Munich, Germany
- Focus on autonomous driving systems and vehicle dynamics
- Engineering foundation in mechanics, control, and embedded systems
Talks & Teaching
Physics-Guided Ultrasound Image Formation
04/2026
Talk · Ultrasound Imaging and Instrumentation Lab (Prof. Jeremy Dahl), Stanford University
(Differentiable) Ray-Based Ultrasound Simulation
07/2025
Invited talk · NVIDIA Holoscan, Advanced Workflows team
Teaching: Computer Aided Medical Procedures I, Computational Surgineering
2023 – 2026
Technical University of Munich · ultrasound imaging lectures and hands-on exercises
Awards & Service
- 2026Best Presentation Award, ASMUS Workshop @ MICCAI, for UltraBend
- 2025Reviewer Award (Honorable Mention), MICCAI
- 2025 – 26MCML AI-X Change Scholarship
- 2024Best Paper Runner-Up Award, ASMUS Workshop @ MICCAI, for PHOCUS
- 2022Runner-Up Award, Hamlyn Winter School on Surgical Imaging and Vision
Reviewing
- ConferencesCVPR, ECCV, MICCAI, MIDL, IPCAI
- JournalsIEEE Transactions on Robotics (T-RO), IEEE Transactions on Automation Science and Engineering (T-ASE)
- WorkshopsASMUS, Off-Grid
Contact
For any research or collaboration enquiries, please do not hesitate to contact me.
Location:
Munich, Germany
Email:
felix-duelmer@online.de
Address:
IFL, Munich, Germany